Overview
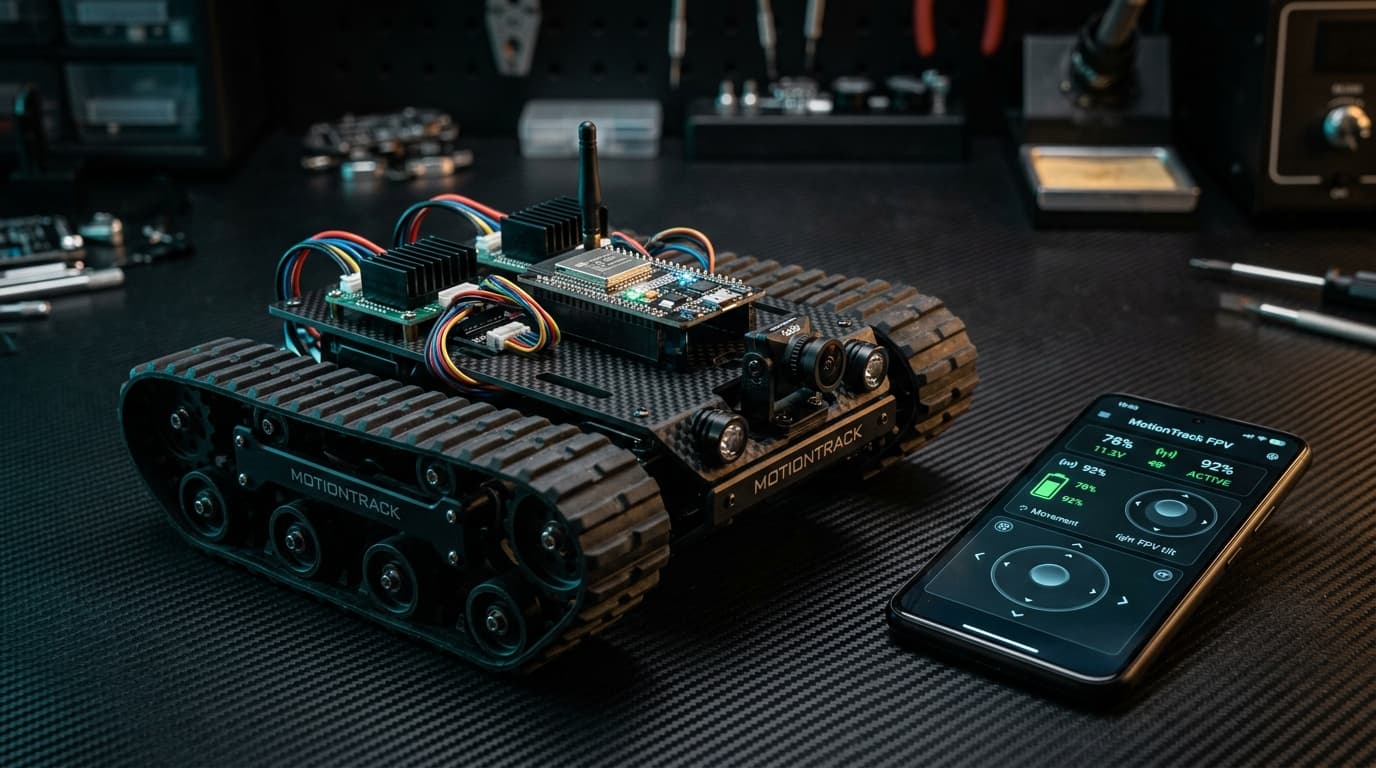
Developed between July and October 2025, the MotionTrack FPV Rover is a responsive robotics research platform designed to explore low-latency teleoperation over Bluetooth Low Energy (BLE) combined with high-current motor drive control.
System Design
1. Embedded On-Board Controller
- Microcontroller: ESP32 running an optimized BLE GATT server service with custom UUIDs for telemetry and motor drive characteristics.
- Drive Electronics: High-power L298N Dual H-Bridge motor driver driving two geared DC motors with hardware PWM duty cycles for smooth acceleration and deceleration curves.
- Power Management: Dual 18650 Li-ion battery pack with an onboard BMS protection circuit and buck converter delivering stable 5V rail logic power.
2. Native Android Controller App
- Built from scratch in Android Studio utilizing Java/Kotlin and Android Material 3 design principles.
- Features a responsive digital gamepad interface simulating dual thumbstick controls, directional pads, and real-time RSSI signal strength monitoring.
- Sends differential steering vectors (V_L, V_R) encoded in compact binary packets over BLE Notification/Write channels with less than 25ms round-trip latency.
Key Learnings & Performance
- Implemented automatic connection recovery and watchdog timers to immediately stop motor movement if wireless link drops.
- Demonstrated reliable telemetry transmission and zero command packet loss across a 20-meter indoor line-of-sight range.
- Repository: GitHub - MotionTrack-FPV-Rover.