Overview
The RF Robotic Arm Control System is a wireless mechatronic project developed between April 2026 and July 2026. The objective was to eliminate latency and signal interference in multi-axis robotic manipulation by developing an ultra-reliable 2.4GHz wireless link between an ergonomic handheld transmitter and an industrial-style 4 Degrees of Freedom (4-DOF) articulation arm.
System Hardware Architecture
The system consists of two primary hardware assemblies:
1. Handheld Dual-Joystick Transmitter
- Controller Core: Arduino Nano running low-power control loops at 100Hz.
- Input Channels: Two 2-axis analog potentiometric joysticks providing 4 continuous degrees of freedom (Base Pan, Shoulder Pitch, Elbow Pitch, and Wrist Elevation), supplemented by discrete tactile switches for pneumatic/servo gripper control.
- RF Module: nRF24L01+ with PA/LNA (Power Amplifier / Low Noise Amplifier) and external SMA duck antenna, operating on 2.4GHz ISM band with enhanced ShockBurst™ packet framing.
2. Robotic Arm Actuation Station
- Processing Core: Arduino Mega 2560 R3, providing 54 digital I/O pins and hardware timers necessary to drive multi-axis stepper step/direction signals without pulse jitter.
- Motor Drive Subsystem: Three A4988 bipolar stepper motor drivers configured in 1/16th microstepping mode, supplying smooth current profiles to NEMA 17 stepper motors.
- End Effector: High-torque metal gear MG996R servo motor providing strong mechanical grip force.
- Power Distribution: Regulated dual-rail power supply isolating high-current motor inductive flyback noise from sensitive microcontroller logic.
Firmware & Motion Control
- Custom Packet Serialization: A compact 12-byte binary payload transmitting raw ADC values, checksum, and button states over the air at 250kbps for maximum receiver sensitivity (-94dBm).
- S-Curve Acceleration & Deceleration: Software trajectory generator preventing mechanical resonance, sudden jerks, and missed motor steps during abrupt joystick deflections.
- Failsafe Watchdog: Automatic motor stop and torque hold if RF packet reception drops for longer than 200ms.
Hardware Wiring Diagrams
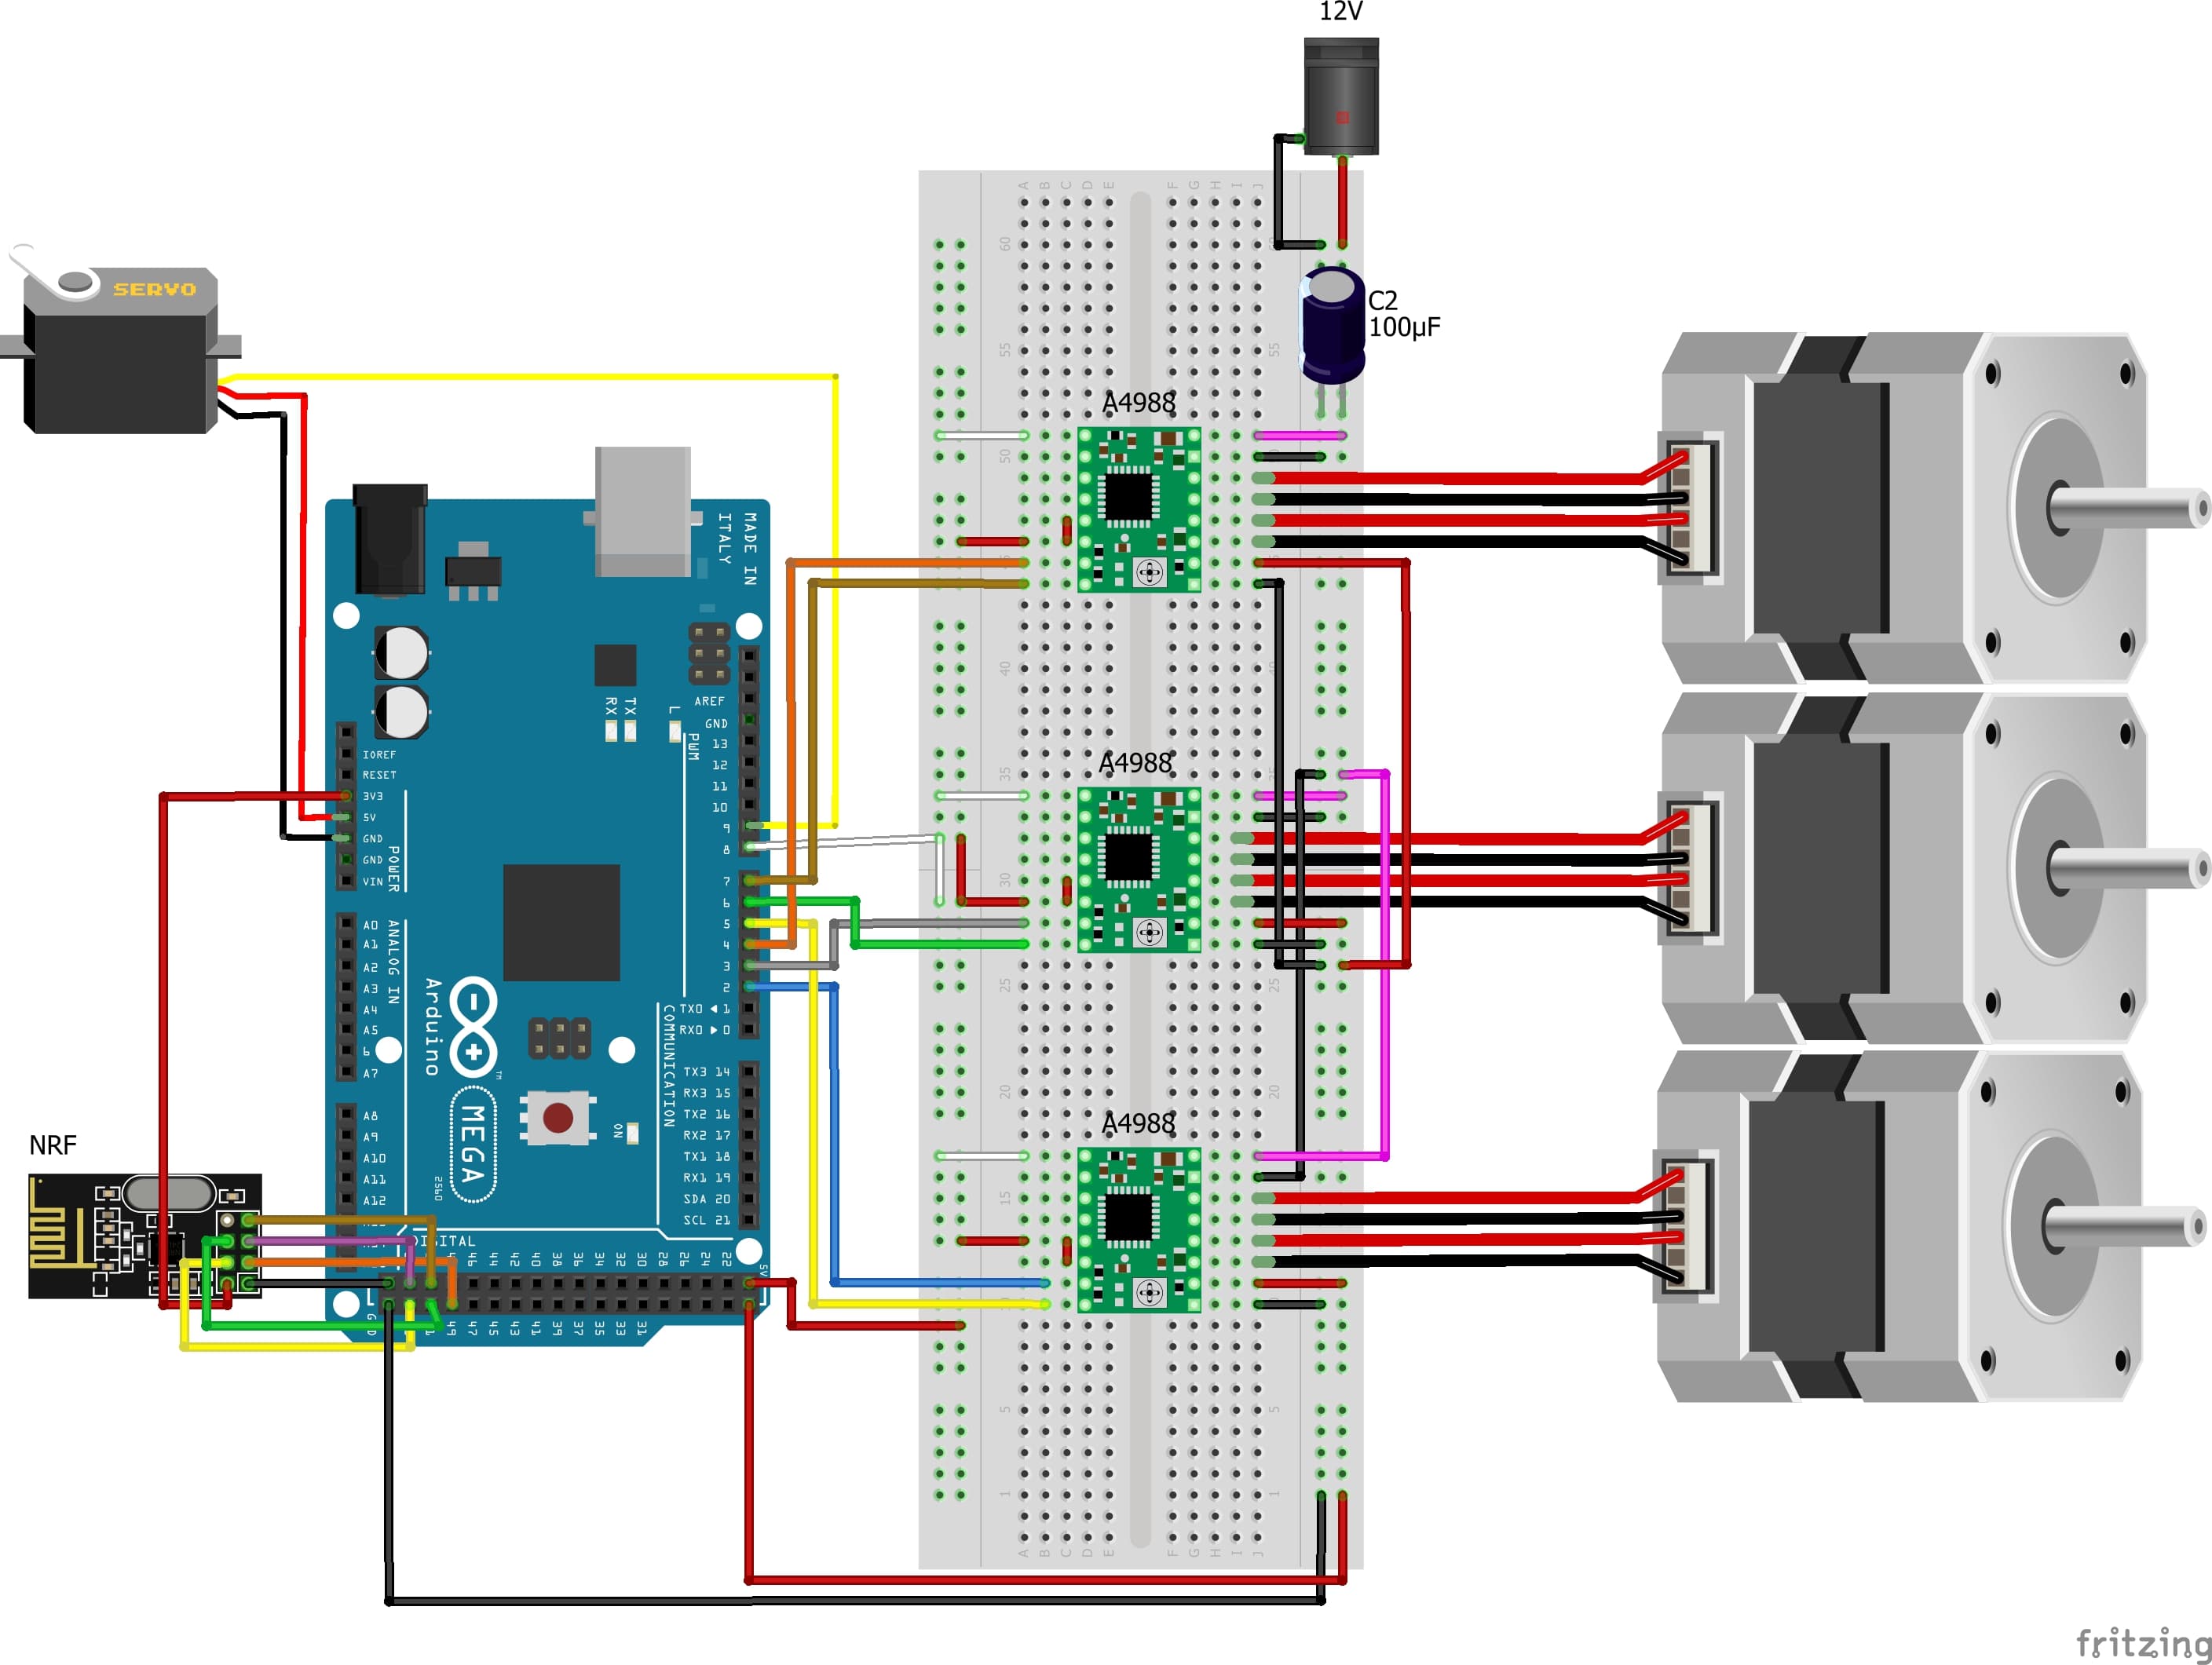
Below are the schematic and breadboard wiring diagrams created and verified during the prototype phase:
- Robotic Arm Receiver & Motor Driver Assembly: Wiring between Arduino Mega 2560, nRF24L01+, and 3x A4988 drivers.
- Handheld Transmitter Module: Connection of dual analog joysticks and RF transmitter unit.
Repository & Source Code
All PCB schematics, component BOM, and Arduino C++ firmware are open-sourced at GitHub - RF-Motor-Control-System.